


AUTONOMOUS WAFFLE CAFE
SUMMARY
Our final robotics assignment was a class-wide project with the goal of creating a fully autonomous waffle making “cafe.” The robot had to be able to take an order, cook the waffle, provide whipped cream, and cut and de-leaf a strawberry for topping. I was assigned to the strawberry team, where we worked to create a machine that could cut the top off of strawberries of different shapes and sizes, with the goal of processing 5 strawberries.
Our subteam was highly collaborative, with many designs going through multiple hands and many iterations in a large shared CAD file, which allowed us to test multiple designs simultaneously and report back on struggles and successes for future iterations.

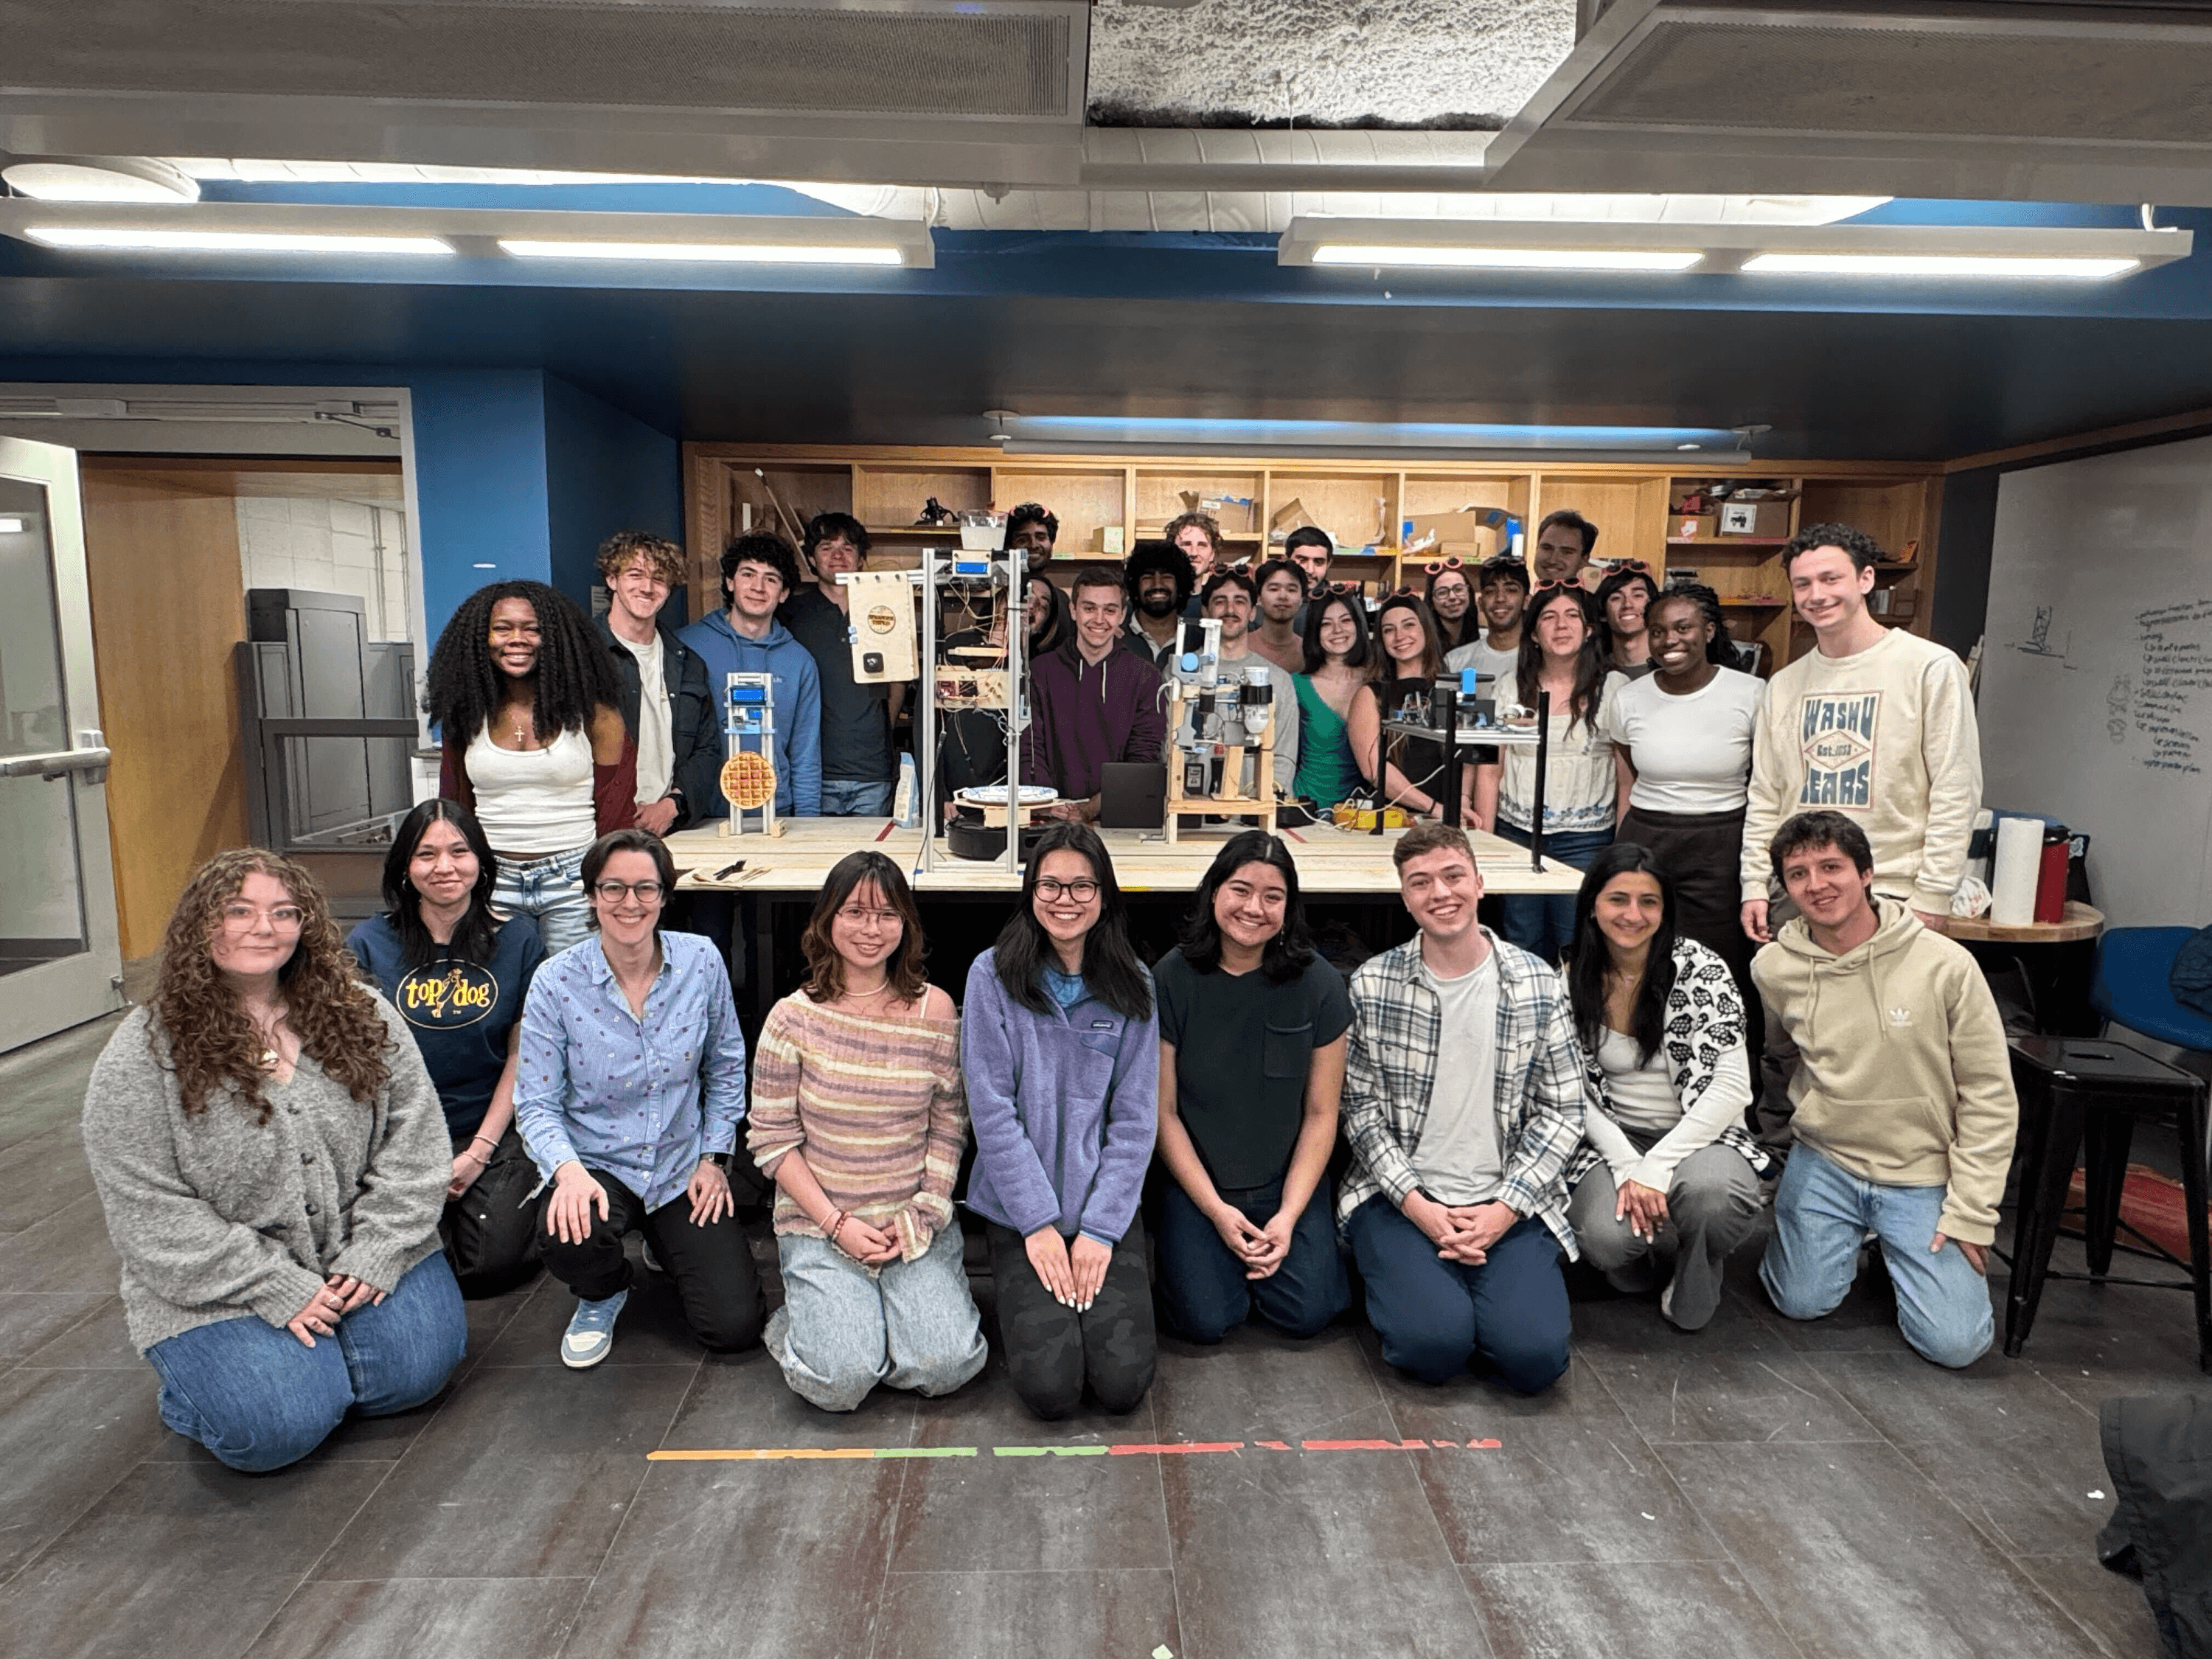
Full Cafe (strawberry bot on right)
DESIGN
Our final component pushed 5 strawberries with dividers through a tube using a rack and pinion. When the strawberry entered the cutting zone as seen by a PiCam, it would send a signal to lower a bench scraper knife to remove the top of the strawberry and deposit it in a waste bin. The picam also tracked the knifes downward movement, stopping it when it reached a lowered threshold. The strawberry would then be pushed out by an servo motor inset into the tube, landing in a second “slicing” pipe. A second rack and pinion would progressively push it forward, repeating the cutting process between each increment and dropping the strawberry slices down onto the waffle below.
DESIGN PROCESS
Our design went through many iterations, with our main constraints being repeatability for all 5 strawberries, gentle handling to prevent damage to the fruit, and tolerances for the knife. By far the largest issue was how different every strawberry can be. Between shape, texture, size, even brand, every strawberry proved to have slightly different behavior.
Additionally, this means that coming up with a way to remove the leaves from the top can be troublesome, as they all
have different amounts of leaf, and are not flat on the top. Initially, we tested pushing strawberries through a tube by themselves, with a limit switch at the end to signal when to cut the strawberries. However, we quickly found that the chain of strawberries would buckle in the middle and push themselves sideways, and the top of the strawberry would sometimes slide over the limit switch all together.
To combat this, we made significant changes to our tube pushing mechanism, providing little dividers that attached on the strawberries tops and provided better motion and separation within the tube, along with maintaining their orientation. Additionally, we made very effort to make the tube as smooth as possible, changing from a 4-step sequence to an 8-step sequence for our rack and pinion.
With these adjustments, we were still running into problems with the limit switch: our design involved a drop-down wastebasket to catch the tops of the strawberries, but the limit switch blocked the deposit, leading the strawberry tops to build up in front of the switch, preventing any further cuts. To solve this, we removed the limit switch and used a color detection system with a PiCam.
UI AND INTEGRATION
To handle integration between sub teams, we had separate UI representatives who worked inter-group to make sure the code would be called at the appropriate time for the appropriate order. In addition to the software integration, we needed to make it physically accessible to the waffle delivering robot. Additionally, our robot was mounted on a sheet of 3mm acrylic, meaning that without stabilization, there was significant bending that affected the gear meshing and positioning of the knife.
To achieve accessibility and stability, I designed a simple adjustable base out of 2020 steel, meant to be modifiable for any heights or design changes to the robot itself, and constructed it with a teammate. This meant we were able to quickly switch the entire robot on and off of the base for testing and adjustments, as well as calibrate its orientation and z axis for the delivery bot.
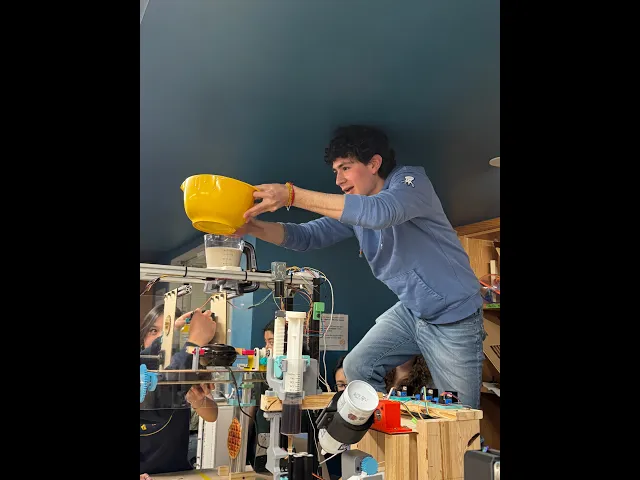
Full-scale waffle test video
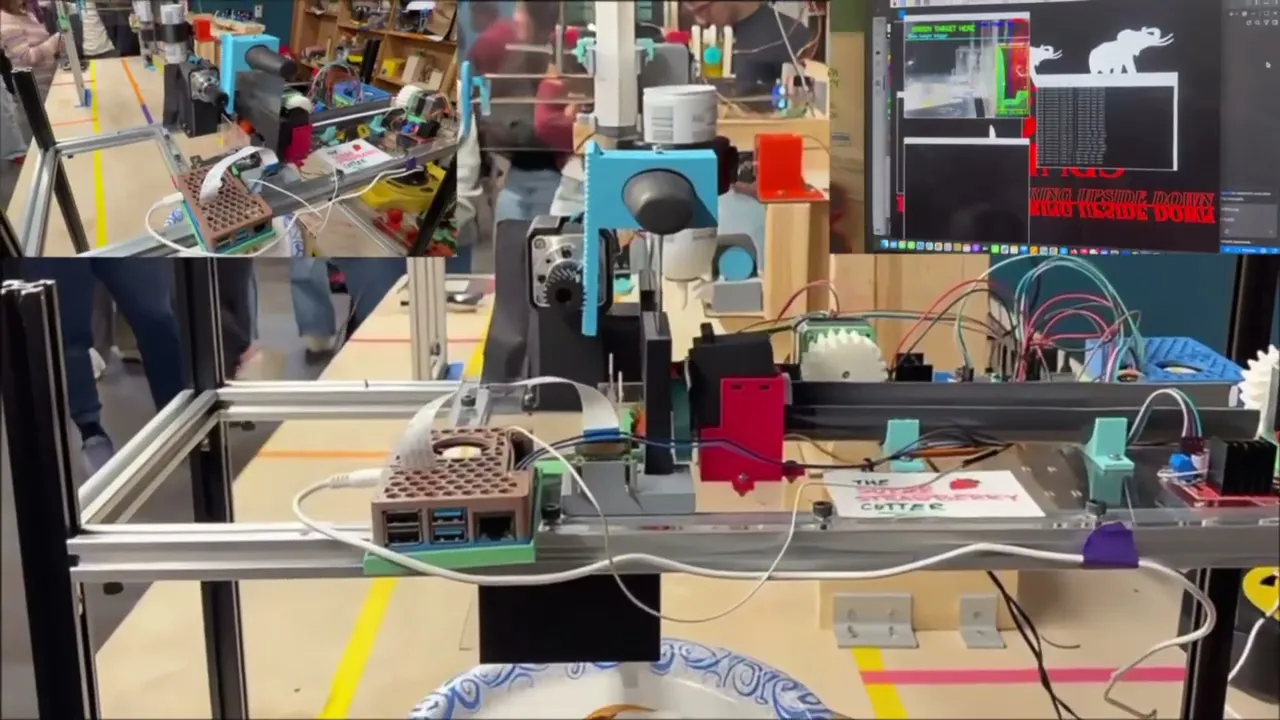
Strawberry only video