



Prototyping, 3D Printing, CAD, Electronics, HTML, Sensors
SUMMARY
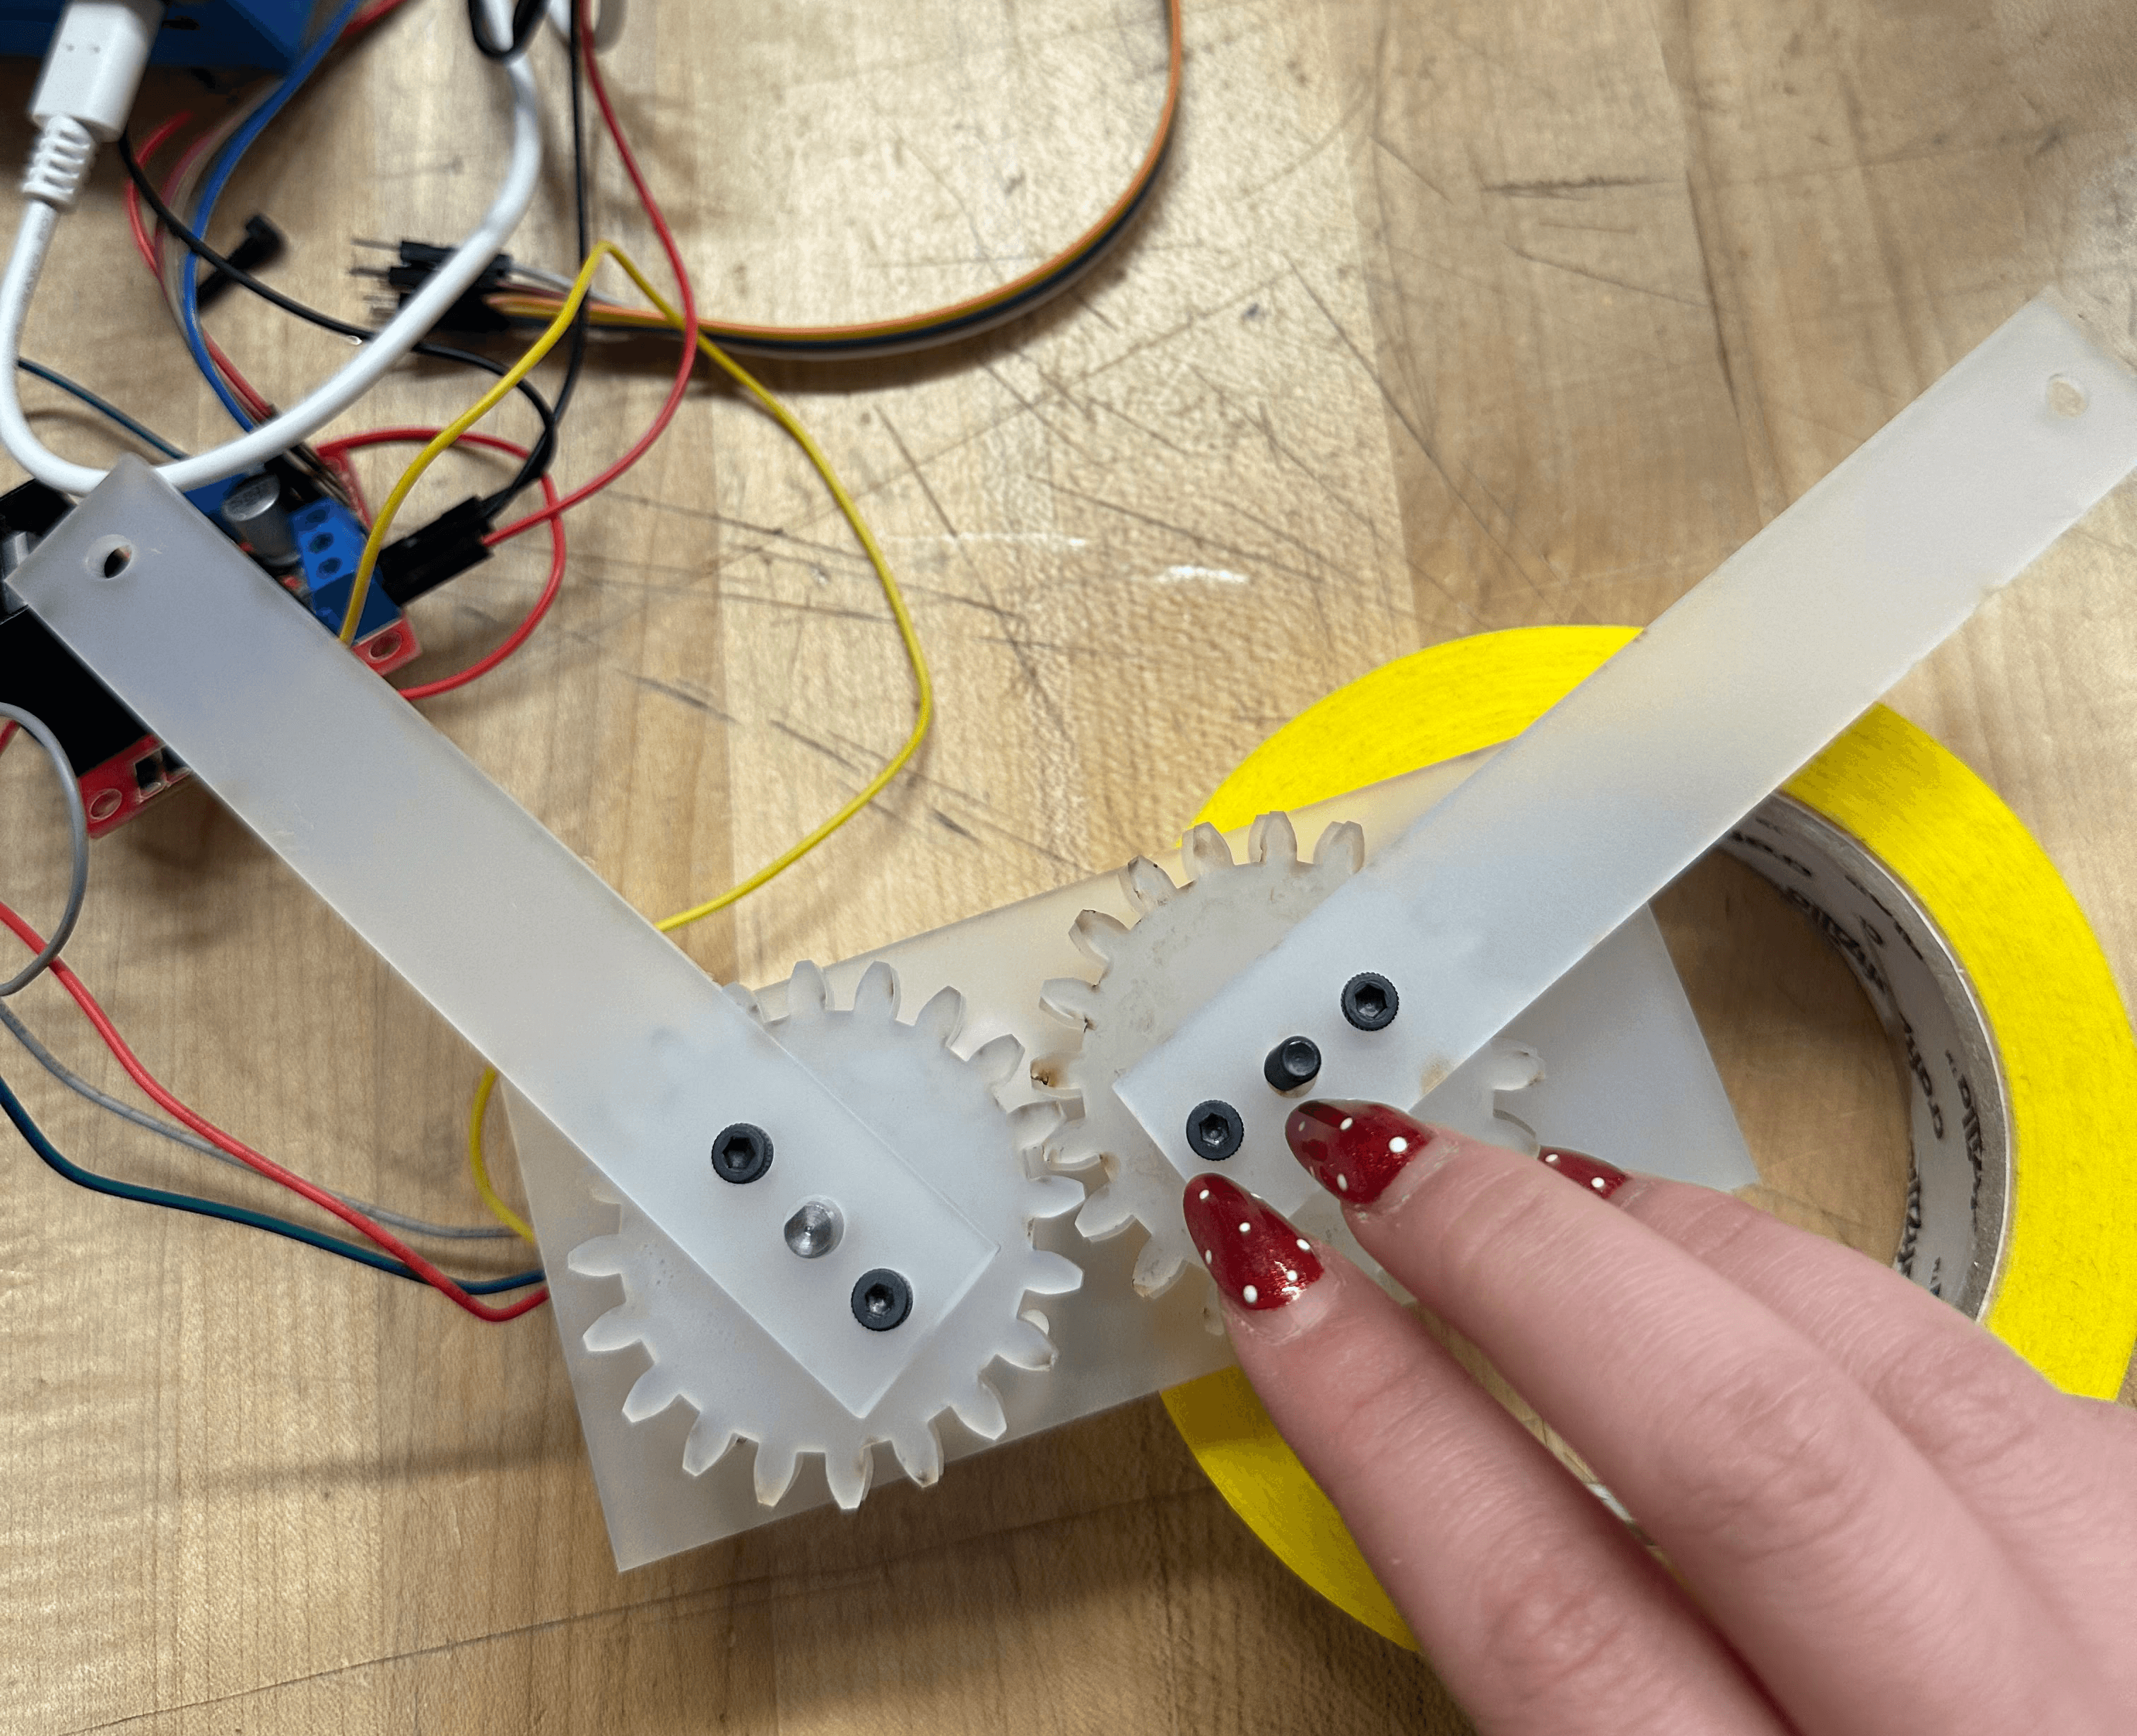
In my introductory robotics course, I worked with a partner to create a grabbing robot with gears and linkages, actuated by a stepper motor. The robot had to be held by only the motor casing, and be able to lift an irregular shape—in our case, a small figurine. For our robot, we focused on creating a design that was modular and could be easily modified with no glue, tape or any other adhesives.
CODING AND ELECTRONICS
We fabricated the arm on this mount and coded it to have an opening and closing mechanism (code linked below.) The raspberry Pi was controlled by a flask file on desktop, which consisted of two buttons that moved the arms 90 degrees.
FINAL PROTOTYPE DESIGN
Our final prototype featured a clear acrylic stand mounted on top of the gears to allow us to hold the motor casing. We mounted the H bridge using screws, while the raspberry pi was fit with low tolerances.


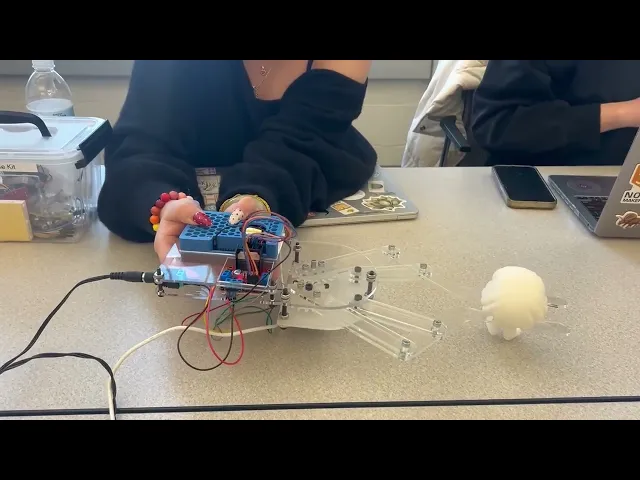
Demonstration of grabber arm