



SUMMARY
For this project, I worked with two other teammates to create an IR line following robot. This project required us to create a sensor array of at least 3 sensors, and follow at least one of two tracks, ranging in difficulty. Our design was driven by two DC motors and was mounted simply on a chassis , with 5 sensors arranged linearly. The code tracked the center position, turning when the sensors on the sides were triggered. We additionally implemented PID control, which allowed us to smooth the motion and complete both the easy and hard tracks.
INITIAL PROTOTYPE DESIGN
Initially, we had a 3 sensor array with our motors mounted under an acrylic chassis. We found that this, paired with the bang bang controller, was too inconsistent and the motors could drag on the ground due to the bending of the acrylic, so we opted to switch the mounting and add additional sensors for later PID control.
Additionally, we found that the sensors were unstable with a single screw, so we added a fitted channel for stability.
PROTOTYPE CHALLENGES
We focused on attempting to create a sensor array that followed the line as closely as possible while still retaining smooth and consistent motion. To reduce jittering and improve sensor accuracy, we placed the sensors close to in-line with the motors turning radius. We lowered the sensors as close to the track as possible, in hopes that it would keep the trackers consistent.

Sensor Array
Our code, created by one of my groupmates, went through multiple iterations starting without any error corrections and eventually containing PID. These error corrections, along with the speed, were tweaked by trial and error to create the most consistent bot we could.
FINAL PROTOTYPE DESIGN

Final Robot Design
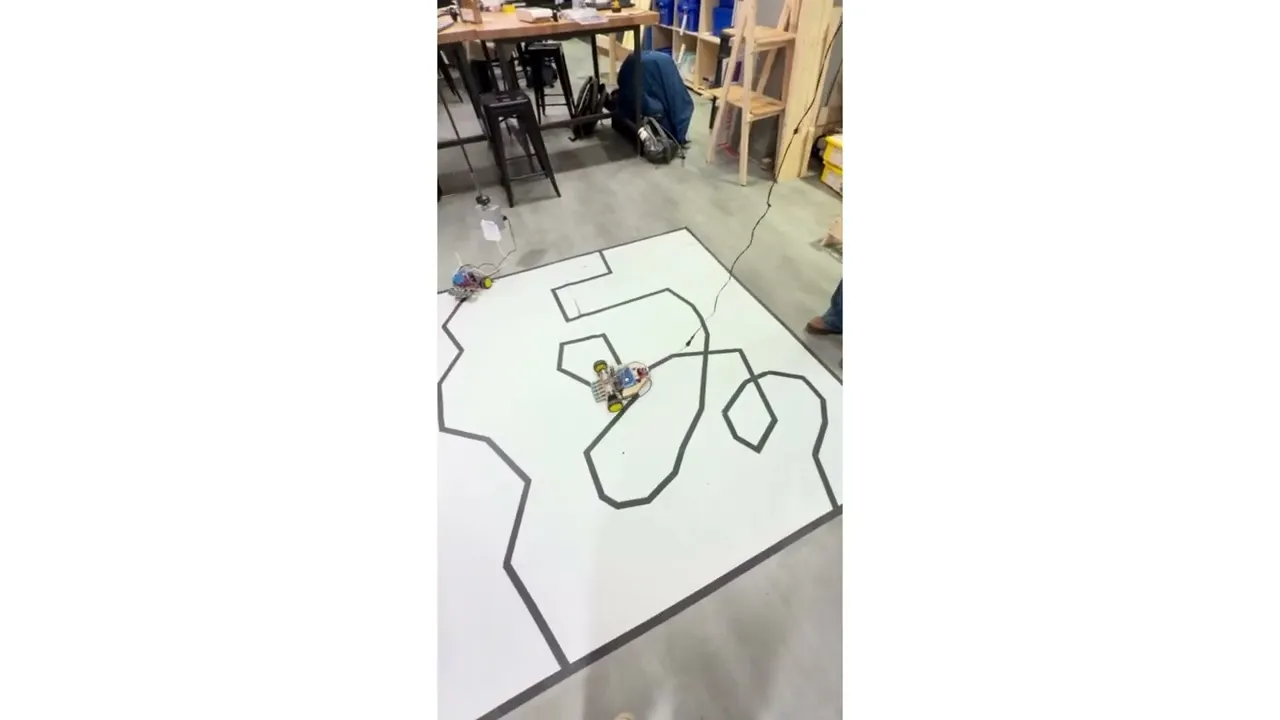
In the end, our robot was able to traverse both the simple and more complex course repeatedly.
Complex Track Demonstration
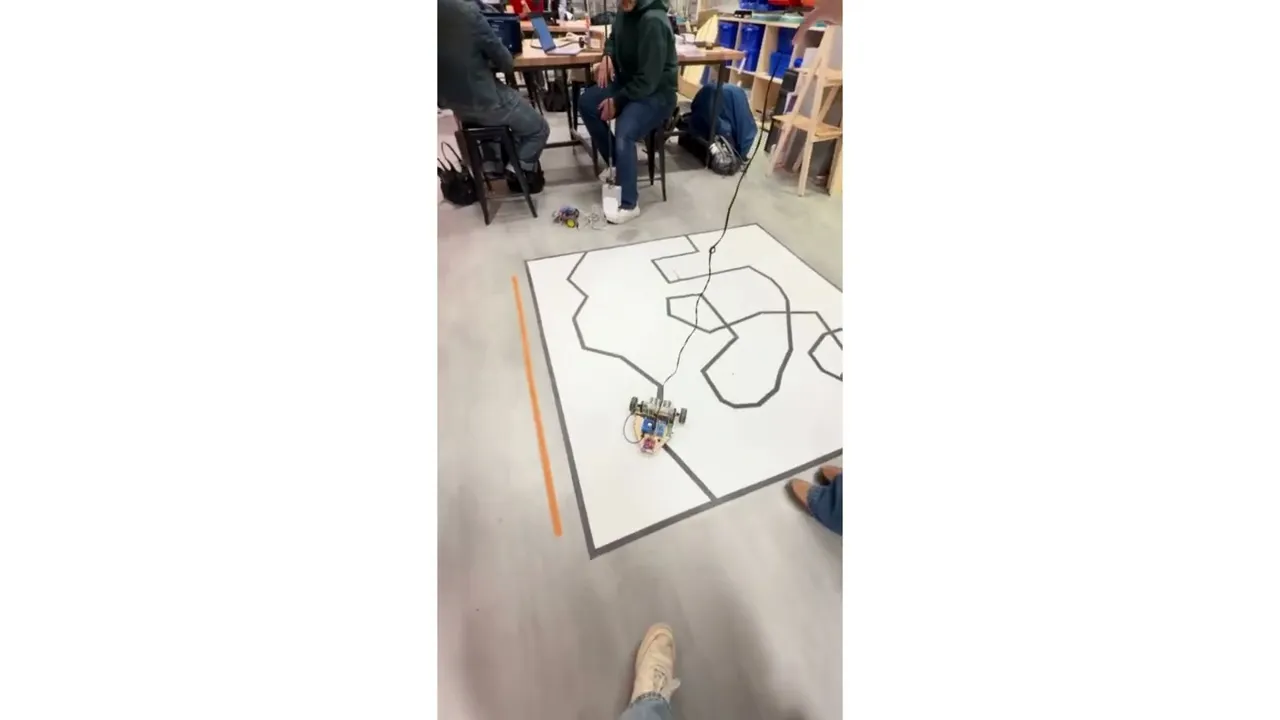
Easy Track Demonstration